Computer Vision
Extracting meaning and building representations of visual objects and events in the world.
Our main research themes cover the areas of deep learning and artificial intelligence for object and action detection, classification and scene understanding, robotic vision and object manipulation, 3D processing and computational geometry, as well as simulation of physical systems to enhance machine learning systems.
Quick Links
-
Researchers
Anoop
Cherian
Tim K.
Marks
Michael J.
Jones
Suhas
Lohit
Chiori
Hori
Kuan-Chuan
Peng
Jonathan
Le Roux
Moitreya
Chatterjee
Siddarth
Jain
Hassan
Mansour
Matthew
Brand
Pedro
Miraldo
Radu
Corcodel
Petros T.
Boufounos
Ye
Wang
Daniel N.
Nikovski
Anthony
Vetro
Gordon
Wichern
William S.
Yerazunis
Toshiaki
Koike-Akino
Dehong
Liu
Yoshiki
Masuyama
Arvind
Raghunathan
Abraham P.
Vinod
Pu
(Perry)
Wang
Avishai
Weiss
Stefano
Di Cairano
Lalit
Manam
Yanting
Ma
Joshua
Rapp
Alexander
Schperberg
Huifang
Sun
Kento
Tomita
Yebin
Wang
Kenji
Inomata
Jing
Liu
Wen-Hsiao
Peng
Kei
Suzuki
-
Awards
-
AWARD MERL Team Wins IROS 2026 Humanoid IKEA Assembly Challenge Date: October 1, 2026
Awarded to: Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, Ye Wang, Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu
MERL Contacts: Toshiaki Koike-Akino; Jing Liu; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
The challenge asked teams to develop autonomous robot policies for a Unitree G1 humanoid robot to assemble an IKEA UTTER table from its component parts. The robot had to perform the task autonomously at the competition venue, requiring capabilities including perception, bimanual manipulation, spatial reasoning, planning, and control. Human intervention was penalized, and teams were evaluated based on assembly progress and completion time.
MERL competed as MEL-Craft and achieved first place in the competition. The result demonstrates progress toward reliable humanoid robots capable of performing complex, contact-rich manipulation tasks in real-world environments, an important direction for physical AI and general-purpose robotic systems.
The MERL team members were Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu.
The Humanoid IKEA Assembly Challenge was held as part of IROS 2026, the IEEE/RSJ International Conference on Intelligent Robots and Systems.
- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
-
AWARD Best Paper - Honorable Mention Award at WACV 2021 Date: January 6, 2021
Awarded to: Rushil Anirudh, Suhas Lohit, Pavan Turaga
MERL Contact: Suhas Lohit
Research Areas: Computational Sensing, Computer Vision, Machine LearningBrief- A team of researchers from Mitsubishi Electric Research Laboratories (MERL), Lawrence Livermore National Laboratory (LLNL) and Arizona State University (ASU) received the Best Paper Honorable Mention Award at WACV 2021 for their paper "Generative Patch Priors for Practical Compressive Image Recovery".
The paper proposes a novel model of natural images as a composition of small patches which are obtained from a deep generative network. This is unlike prior approaches where the networks attempt to model image-level distributions and are unable to generalize outside training distributions. The key idea in this paper is that learning patch-level statistics is far easier. As the authors demonstrate, this model can then be used to efficiently solve challenging inverse problems in imaging such as compressive image recovery and inpainting even from very few measurements for diverse natural scenes.
- A team of researchers from Mitsubishi Electric Research Laboratories (MERL), Lawrence Livermore National Laboratory (LLNL) and Arizona State University (ASU) received the Best Paper Honorable Mention Award at WACV 2021 for their paper "Generative Patch Priors for Practical Compressive Image Recovery".
-
AWARD MERL Researchers win Best Paper Award at ICCV 2019 Workshop on Statistical Deep Learning in Computer Vision Date: October 27, 2019
Awarded to: Abhinav Kumar, Tim K. Marks, Wenxuan Mou, Chen Feng, Xiaoming Liu
MERL Contact: Tim K. Marks
Research Areas: Artificial Intelligence, Computer Vision, Machine LearningBrief- MERL researcher Tim Marks, former MERL interns Abhinav Kumar and Wenxuan Mou, and MERL consultants Professor Chen Feng (NYU) and Professor Xiaoming Liu (MSU) received the Best Oral Paper Award at the IEEE/CVF International Conference on Computer Vision (ICCV) 2019 Workshop on Statistical Deep Learning in Computer Vision (SDL-CV) held in Seoul, Korea. Their paper, entitled "UGLLI Face Alignment: Estimating Uncertainty with Gaussian Log-Likelihood Loss," describes a method which, given an image of a face, estimates not only the locations of facial landmarks but also the uncertainty of each landmark location estimate.
See All Awards for Computer Vision -
-
News & Events
-
NEWS MERL contributes to IROS 2026 Date: September 27, 2026 - October 1, 2026
Where: The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
MERL Contacts: Siddarth Jain; Toshiaki Koike-Akino; Jing Liu; Daniel N. Nikovski; Arvind Raghunathan; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
Main Conference Paper
- ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation, Yunfu Deng and Daniel N. Nikovski (TR2026-141)
The work introduces a geometric representation for articulated-object manipulation, enabling robots to infer compact representations of previously unknown articulated mechanisms for downstream learning and control.
Workshop Papers
- Deliberate Practice: Learning Robot Skills under a Budget Shivam Vats, Sudarshan Harithas, Mete Akbulut, Arvind Raghunathan, and George Konidaris (TR2026-147)
- ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies, Haodi Hu, Chung-Ta Huang, Jing Liu, Ye Wang, Kei Suzuki, Matthew Brand, and Toshiaki Koike-Akino (TR2026-148)
- Test-Time Attention: Can Robots Better Follow Commands? Jing Liu, Ye Wang, Kei Suzuki, and Toshiaki Koike-Akino (TR2026-142)
- Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation, Chak Lam Shek, Ye Wang, Jing Liu, Kei Suzuki, Pratap Tokekar, and Toshiaki Koike-Akino (TR2026-149)
- DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments, Harsh Singh, Kei Suzuki, Ye Wang, Jing Liu, Paola Cascante-Bonilla, and Toshiaki Koike-Akino (TR2026-146)
Together, these works address a range of challenges in modern robotics, including articulated-object manipulation, efficient robot skill learning, vision-language-action policies, test-time adaptation, autonomous factory operation, and dynamic manipulation. The paper on ReCoVLA was nominated as a spotlight talk.
Robotics Community Contributions
MERL Principal Research Scientist Dr. Siddarth Jain participated in the IEEE Robotics and Automation Letters (RA-L) editorial board meeting at IROS. Dr. Jain serves as an Associate Editor of RA-L, contributing to the peer-review and editorial activities of the robotics research community.
Former MERL scientist Dr. Diego Romeres was also among the organizers of the 1st International Workshop on Industrial Applications of Robot Learning (IARL 2026). The workshop brought together researchers from academia and industry to discuss how advances in robot learning can be translated into reliable and scalable real-world industrial robotic systems.
Humanoid IKEA Assembly Challenge
MERL also participated in the IROS 2026 Humanoid IKEA Assembly Challenge with Team MEL-Craft. The team achieved first place in the competition, demonstrating autonomous humanoid manipulation capabilities for a challenging furniture-assembly task. The MEL-Craft team included MERL researchers Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Haodi Hu, Harsh Singh, Chak Lam Shek, and Maxwell Asselmeier. The competition achievement is highlighted separately in MERL's related award announcement.
About IROS
The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) is a major international robotics conference bringing together researchers, engineers, and industry practitioners working across intelligent robots and systems. IROS 2026 took place in Pittsburgh from September 27 to October 1, 2026.
- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
-
NEWS MERL Presents 4 Main Conference Papers and 6 Workshop Papers at ICML 2026 Date: July 6, 2026 - July 11, 2026
Where: COEX, Seoul, South Korea
MERL Contacts: Moitreya Chatterjee; Anoop Cherian; Stefano Di Cairano; Toshiaki Koike-Akino; Christopher R. Laughman; Jing Liu; Suhas Lohit; Kuan-Chuan Peng; Alexander Schperberg; Ye Wang; Gordon Wichern
Research Areas: Artificial Intelligence, Computer Vision, Machine Learning, Signal ProcessingBrief- MERL researchers are proud to present 4 main conference papers and 6 workshop papers at ICML 2026. ICML, taking place from July 6-11 in Seoul, South Korea, is a premier international conference in machine learning.
Main Conference Papers with MERL Authors:
1. Understanding Dynamic Compute Allocation in Recurrent Transformers by Ibraheem Muhammad Moosa, Suhas Lohit, Ye Wang, Moitreya Chatterjee, and Wenpeng Yin.
2. LLawCo: Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior by Qinhong Zhou, Chuang Gan, and Anoop Cherian.
3. Memory-Distilled Selection for Noise-Robust Anomaly Detection by Sirojbek Safarov, Jaewoo Park, Yoon G. Jung, Kuan-Chuan Peng, Wonchul Kim, Seongdeok Bang, and Octavia Camps.
4. Partial Ring Scan: Revisiting Scan Order in Vision State Space Models by Yi-Kuan Hsieh, Kuan-Chuan Peng, Xin Li, Ming-Ching Chang, Yu-Chee Tseng, and Jun-Wei Hsieh.
Workshop Papers with MERL Authors:
1. WISE: Weighted Iterative Society-of-Experts for Multimodal Multi-Agent Debate with Probabilistic Consensus by Anoop Cherian, Suhas Lohit, and Kuan-Chuan Peng. (Workshop on Scalable Learning and Optimization for Efficient Multimodal AI Agents (SCALE))
2. MIRROR: Multisensory Implicit Rejection-sampled RObotic policy by Amisha Bhaskar, Pratap Tokekar, Stefano Di Cairano, and Alexander Schperberg. (Workshop on Structured Probabilistic Inference & Generative Modeling)
3. Reinforced Neural Processes: Memory-Efficient Time-Series Forecasting with a World-Feedback-Trained Memory Policy by Nibraas Khan, Gordon Wichern, and Christopher R. Laughman. (Workshop on Reinforcement Learning from World Feedback (RLxF))
4. Connecting Low-Rank Adapters and Policy Stability in GRPO Fine-Tuning by Antonin Rottman, Francesco Tonin, Yongtao Wu, Toshiaki Koike-Akino, and Volkan Cevher. (Workshop on Connecting Low-rank Representations in AI (CoLorAI))
5. EinSort: Sorting is All We Need for Tensorizing LLM by Toshiaki Koike-Akino, Jing Liu, and Ye Wang. (Workshop on Connecting Low-rank Representations in AI (CoLorAI))
6. Temper and Tilt Lead to SLOP: Reward Hacking Mitigation with Inference-Time Alignment by Ye Wang, and Jing Liu, and Toshiaki Koike-Akino. (Workshop on Agents in the Wild: Safety, Security, and Beyond)
- MERL researchers are proud to present 4 main conference papers and 6 workshop papers at ICML 2026. ICML, taking place from July 6-11 in Seoul, South Korea, is a premier international conference in machine learning.
See All News & Events for Computer Vision -
-
Research Highlights
-
LLawCo: Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior -
Point4Cast: Streaming Dynamic Scene Reconstruction and Forecasting -
AssemblyBench: Physics-Aware Assembly of Complex Industrial Objects -
SLAM-MER: Revisiting Monocular SLAM with Spatio-Temporal Scene Modeling -
Parallel Rigidity Matters for Bundle Adjustment -
LLMPhy: Parameter-Identifiable Physical Reasoning Combining Large Language Models and Physics Engines -
SAC-GNC: SAmple Consensus for adaptive Graduated Non-Convexity -
PS-NeuS: A Probability-guided Sampler for Neural Implicit Surface Rendering -
TI2V-Zero: Zero-Shot Image Conditioning for Text-to-Video Diffusion Models -
Gear-NeRF: Free-Viewpoint Rendering and Tracking with Motion-Aware Spatio-Temporal Sampling -
Steered Diffusion -
Robust Machine Learning -
Video Anomaly Detection -
MERL Shopping Dataset -
Point-Plane SLAM
-
-
Internships
-
CV0075: Internship - Multimodal Embodied AI
-
OR0317: Internship - Vision-Language-Action (VLA) Models for Robotic Manipulation
-
CV0101: Internship - Multimodal Algorithmic Reasoning
See All Internships for Computer Vision -
-
Openings
See All Openings at MERL -
Recent Publications
- , "Plan and Double-Check: Streaming Multimodal Q-Former for Online Robot Action Generation", Interspeech, September 2026.BibTeX TR2026-136 PDF
- @inproceedings{Hori2026sep,
- author = {{Hori, Chiori and Korekata, Ryosuke and Kambara, Motonari and Masuyama, Yoshiki and Jain, Siddarth and Corcodel, Radu and Romeres, Diego and Le Roux, Jonathan}},
- title = {{Plan and Double-Check: Streaming Multimodal Q-Former for Online Robot Action Generation}},
- booktitle = {Interspeech},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-136}
- }
- , "Language Models in Video Anomaly Detection: A Dynamic Survey", IEEE Access, September 2026.BibTeX TR2026-143 PDF
- @article{Mumcu2026sep,
- author = {Mumcu, Furkan and Bekit, Lokman and Jones, Michael J. and Cherian, Anoop and Yilmaz, Yasin},
- title = {{Language Models in Video Anomaly Detection: A Dynamic Survey}},
- journal = {IEEE Access},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-143}
- }
- , "LEAP-VLA: Latent-Enhanced Action Prototyping via Continuous Residual Latent Spaces for Vision-Language-Action Models", European Conference on Computer Vision (ECCV), Favaro, P. and Kukelova, Z. and Maki, A. and Rohrbach, A. and Schindler, K. and Tombari, F., Eds., DOI: 10.1007/978-3-032-37450-9_20, September 2026, vol. 17034, pp. 367–385.BibTeX TR2026-127 PDF
- @inproceedings{Yu2026sep,
- author = {Yu, Bo-Yun and Peng, Kuan-Chuan and Hsieh, Jun-Wei},
- title = {{LEAP-VLA: Latent-Enhanced Action Prototyping via Continuous Residual Latent Spaces for Vision-Language-Action Models}},
- booktitle = {European Conference on Computer Vision (ECCV)},
- year = 2026,
- editor = {Favaro, P. and Kukelova, Z. and Maki, A. and Rohrbach, A. and Schindler, K. and Tombari, F.},
- volume = 17034,
- pages = {367–385},
- month = sep,
- publisher = {Springer},
- doi = {10.1007/978-3-032-37450-9_20},
- issn = {0302-9743},
- isbn = {978-3-032-37449-3},
- url = {https://www.merl.com/publications/TR2026-127}
- }
- , "Partial Ring Scan: Revisiting Scan Order in Vision State Space Models", International Conference on Machine Learning (ICML), Zhang, T. and Dudik, M. and Jaggi, M. and Agarwal, A. and Li, S. and Schuurmans, D. and Zhu, J. and Berkenkamp, F. and Dong, H. and Bietti, A., Eds., July 2026, vol. 306, pp. 44412-44432.BibTeX TR2026-091 PDF
- @inproceedings{Hsieh2026jul,
- author = {Hsieh, Yi-Kuan and Peng, Kuan-Chuan and Li, Xin and Chang, Ming-Ching and Tseng, Yu-Chee and Hsieh, Jun-Wei},
- title = {{Partial Ring Scan: Revisiting Scan Order in Vision State Space Models}},
- booktitle = {International Conference on Machine Learning (ICML)},
- year = 2026,
- editor = {Zhang, T. and Dudik, M. and Jaggi, M. and Agarwal, A. and Li, S. and Schuurmans, D. and Zhu, J. and Berkenkamp, F. and Dong, H. and Bietti, A.},
- volume = 306,
- pages = {44412--44432},
- month = jul,
- publisher = {Proceedings of Machine Learning Research (PMLR)},
- url = {https://www.merl.com/publications/TR2026-091}
- }
- , "Understanding Dynamic Compute Allocation in Recurrent Transformers", International Conference on Machine Learning (ICML), Zhang, Tong and Dudik, Miroslav and Jaggi, Martin and Agarwal, Alekh and Li, Sharon and Schuurmans, Dale and Zhu, Jerry and Berkenkamp, Felix and Dong, Hanze and Bietti, Alberto, Eds., July 2026, vol. 306, pp. 90213-90231.BibTeX TR2026-090 PDF Software Presentation
- @inproceedings{Moosa2026jul,
- author = {{Moosa, Ibraheem Muhammad and Lohit, Suhas and Wang, Ye and Chatterjee, Moitreya and Yin, Wenpeng}},
- title = {{Understanding Dynamic Compute Allocation in Recurrent Transformers}},
- booktitle = {Proceedings of the 43rd International Conference on Machine Learning},
- year = 2026,
- editor = {Zhang, Tong and Dudik, Miroslav and Jaggi, Martin and Agarwal, Alekh and Li, Sharon and Schuurmans, Dale and Zhu, Jerry and Berkenkamp, Felix and Dong, Hanze and Bietti, Alberto},
- volume = 306,
- pages = {90213--90231},
- month = jul,
- publisher = {PMLR},
- issn = {2640-3498},
- url = {https://www.merl.com/publications/TR2026-090}
- }
- , "Memory-Distilled Selection for Noise-Robust Anomaly Detection", International Conference on Machine Learning (ICML), Zhang, T. and Dudik, M. and Jaggi, M. and Agarwal, A. and Li, S. and Schuurmans, D. and Zhu, J. and Berkenkamp, F. and Dong, H. and Bietti, A., Eds., July 2026, vol. 306, pp. 106818-106844.BibTeX TR2026-089 PDF
- @inproceedings{Safarov2026jul,
- author = {{Safarov, Sirojbek and Park, Jaewoo and Jung, Yoon G. and Peng, Kuan-Chuan and Kim, Wonchul and Bang, Seongdeok and Camps, Octavia}},
- title = {{Memory-Distilled Selection for Noise-Robust Anomaly Detection}},
- booktitle = {International Conference on Machine Learning (ICML)},
- year = 2026,
- editor = {Zhang, T. and Dudik, M. and Jaggi, M. and Agarwal, A. and Li, S. and Schuurmans, D. and Zhu, J. and Berkenkamp, F. and Dong, H. and Bietti, A.},
- volume = 306,
- pages = {106818--106844},
- month = jul,
- publisher = {Proceedings of Machine Learning Research (PMLR)},
- url = {https://www.merl.com/publications/TR2026-089}
- }
- , "WISE: Weighted Iterative Society-of-Experts for Multimodal Multi-Agent Debate with Probabilistic Consensus", ICML SCALE AI Workshop, June 2026.BibTeX TR2026-083 PDF
- @inproceedings{Cherian2026jun,
- author = {Cherian, Anoop and Lohit, Suhas and Peng, Kuan-Chuan},
- title = {{WISE: Weighted Iterative Society-of-Experts for Multimodal Multi-Agent Debate with Probabilistic Consensus}},
- booktitle = {ICML SCALE AI Workshop},
- year = 2026,
- month = jun,
- url = {https://www.merl.com/publications/TR2026-083}
- }
- , "LLawCo: Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior", International Conference on Machine Learning (ICML), June 2026, vol. 306, pp. 164849-164866.BibTeX TR2026-081 PDF Video Software
- @inproceedings{Zhou2026jun,
- author = {Zhou, Qinhong and Gan, Chuang and Cherian, Anoop},
- title = {{LLawCo: Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior}},
- booktitle = {Proceedings of the 43rd International Conference on Machine Learning},
- year = 2026,
- volume = 306,
- pages = {164849--164866},
- month = jun,
- publisher = {PMLR},
- url = {https://www.merl.com/publications/TR2026-081}
- }
- , "Plan and Double-Check: Streaming Multimodal Q-Former for Online Robot Action Generation", Interspeech, September 2026.
-
Videos
-
Software & Data Downloads
-
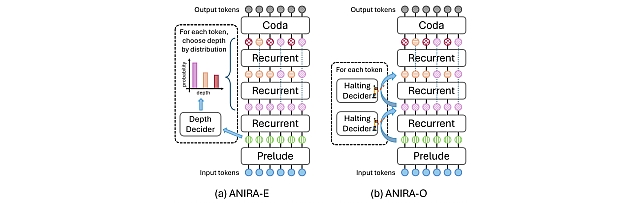
Understanding Dynamic Compute Allocation in Recurrent Transformers -
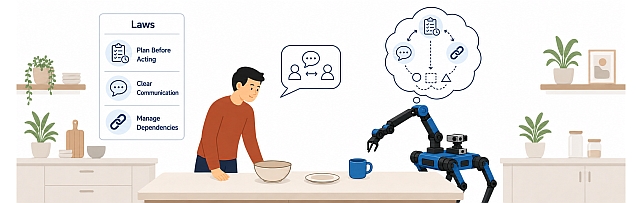
Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior -
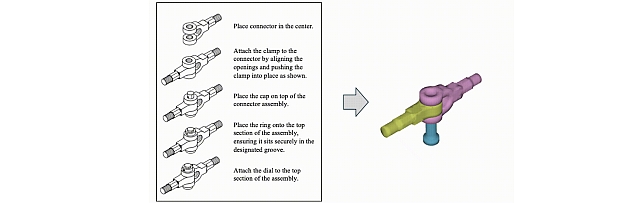
Physics-Aware Assembly of Complex Industrial Objects -
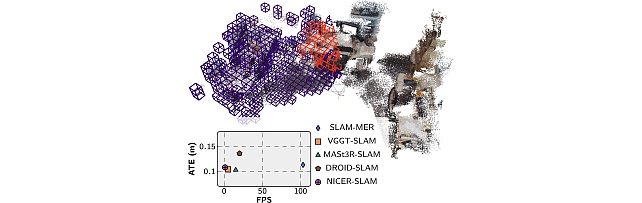
Mitsubishi Electric Research framework for visual SLAM -
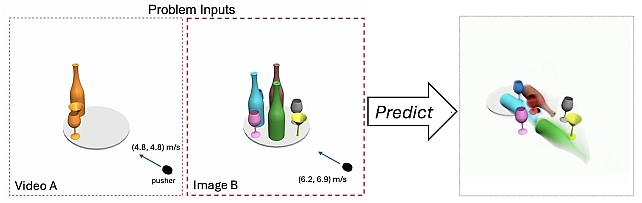
Parameter-Identifiable Physical Reasoning Combining Large Language Models and Physics Engines -

MMHOI Dataset: Modeling Complex 3D Multi-Human Multi-Object Interactions -
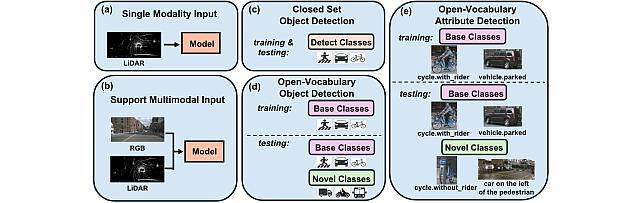
Open Vocabulary Attribute Detection Dataset -
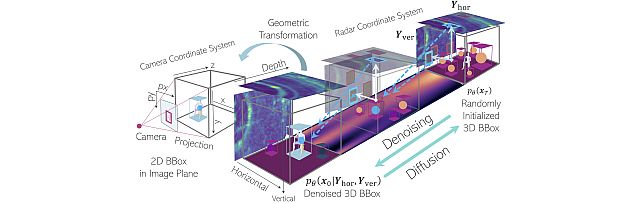
multi-view Radar object dEtection with 3D bounding boX diffusiOn -
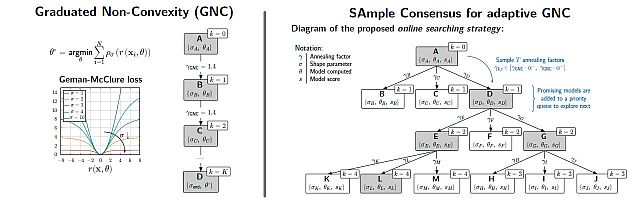
SAmple Consensus for Adaptive Graduated Non-Convexity -
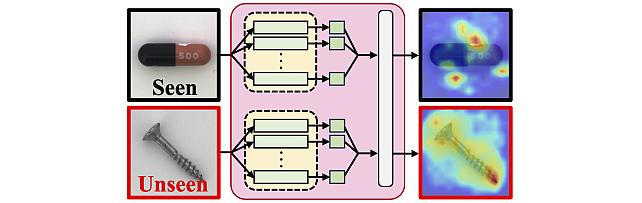
Long-Tailed Online Anomaly Detection dataset -
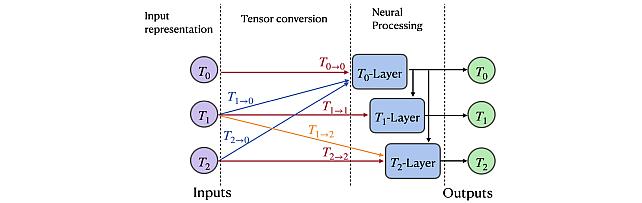
Group Representation Networks -
ComplexVAD Dataset -

Zero-Shot Image Conditioning for Text-to-Video Diffusion Models -
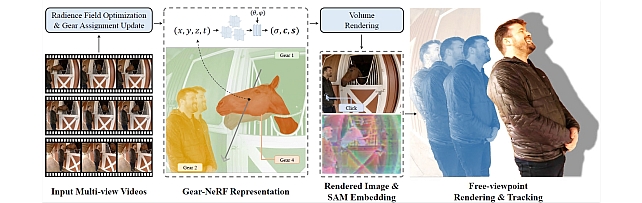
Gear Extensions of Neural Radiance Fields -
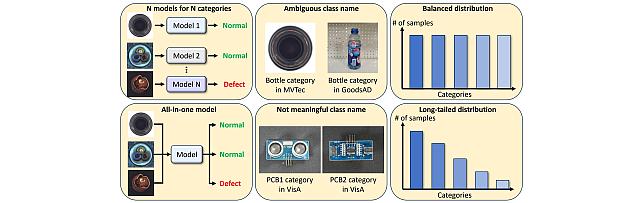
Long-Tailed Anomaly Detection Dataset -
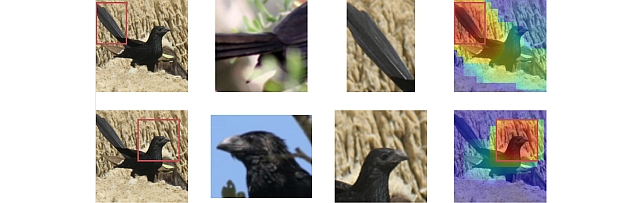
Pixel-Grounded Prototypical Part Networks -
Steered Diffusion -
BAyesian Network for adaptive SAmple Consensus -
Robust Frame-to-Frame Camera Rotation Estimation in Crowded Scenes
-
Explainable Video Anomaly Localization -
Simple Multimodal Algorithmic Reasoning Task Dataset -
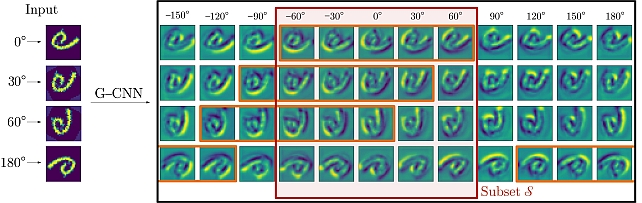
Partial Group Convolutional Neural Networks -
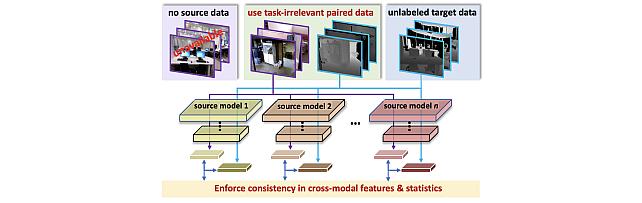
SOurce-free Cross-modal KnowledgE Transfer -
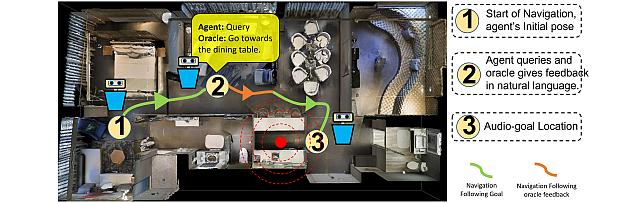
Audio-Visual-Language Embodied Navigation in 3D Environments -
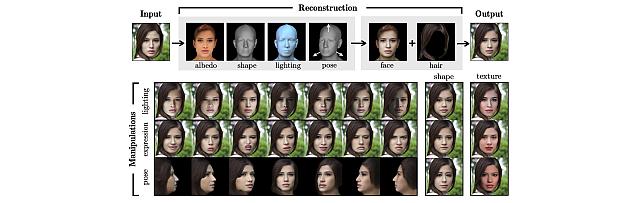
3D MOrphable STyleGAN -
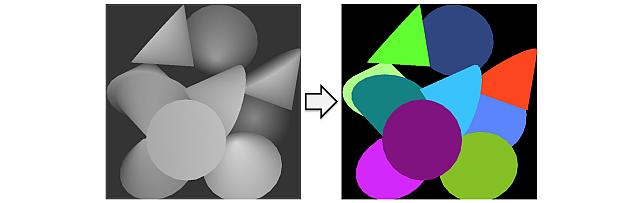
Instance Segmentation GAN -
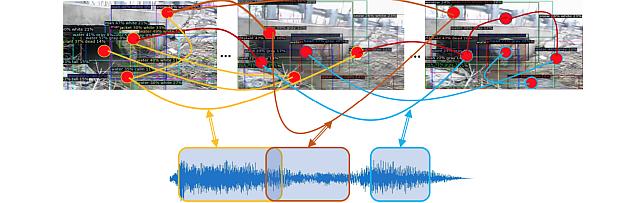
Audio Visual Scene-Graph Segmentor -
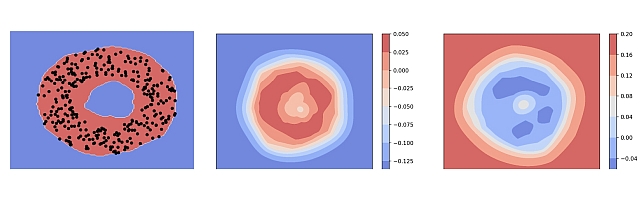
Generalized One-class Discriminative Subspaces -
Generating Visual Dynamics from Sound and Context -
Adversarially-Contrastive Optimal Transport -
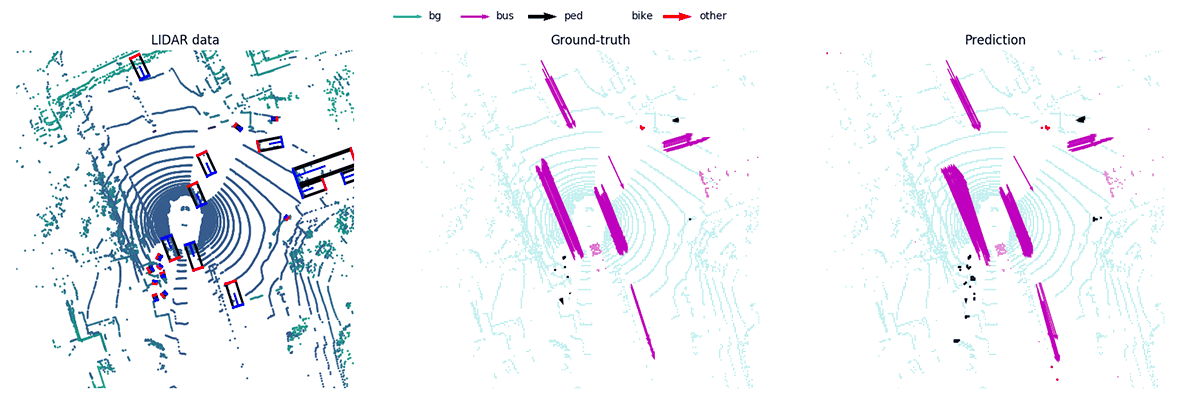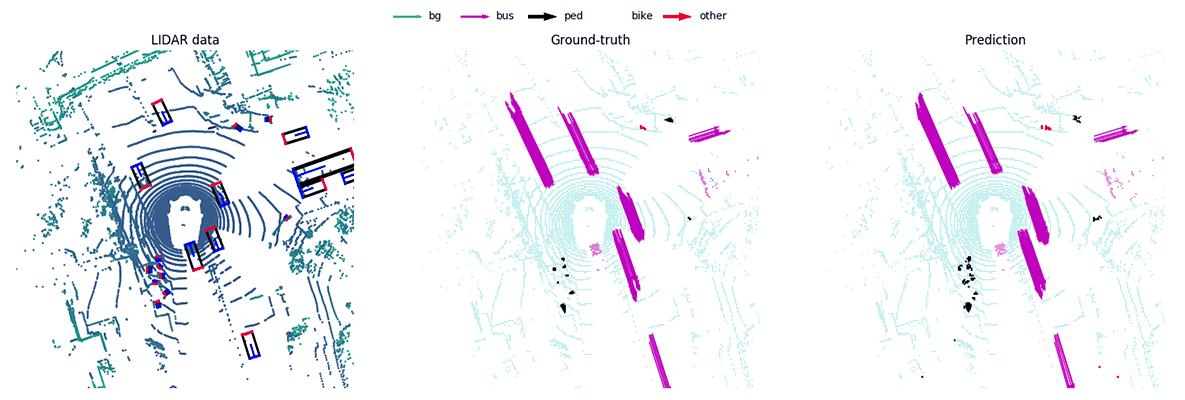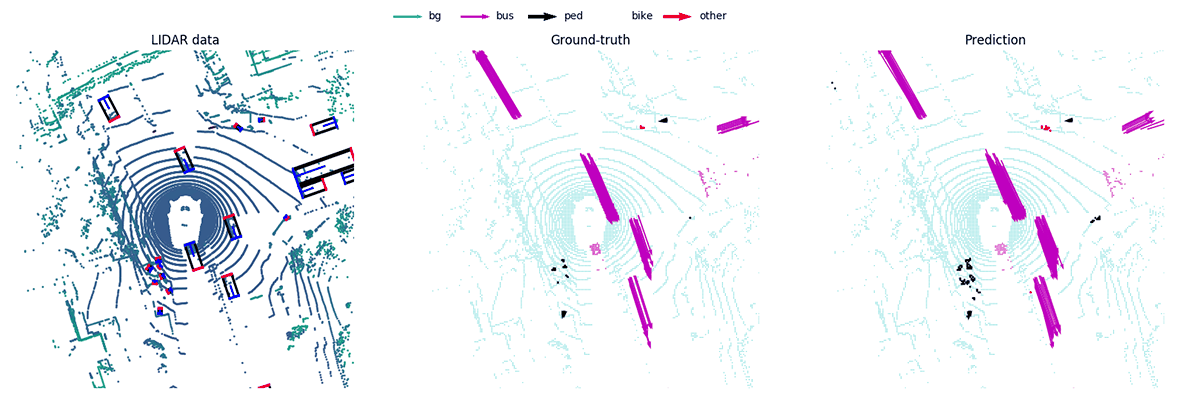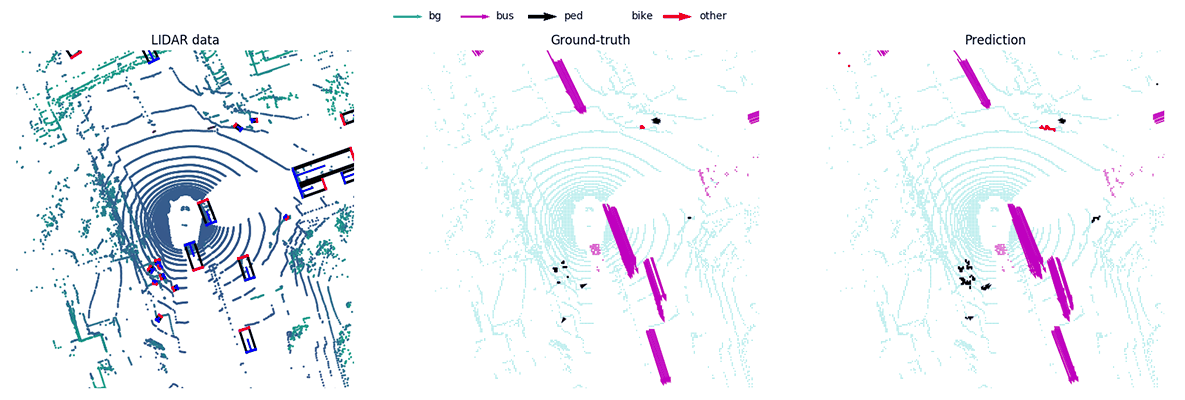
MotionNet -
Street Scene Dataset -
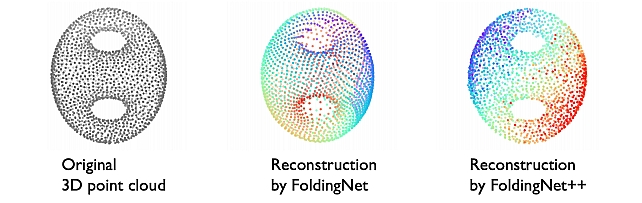
FoldingNet++ -
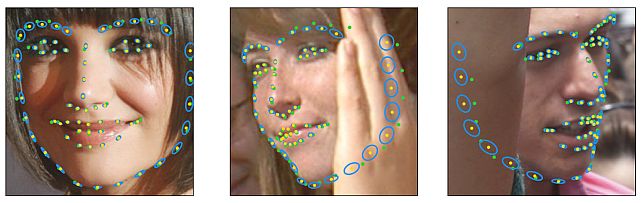
Landmarks’ Location, Uncertainty, and Visibility Likelihood -
Gradient-based Nikaido-Isoda -
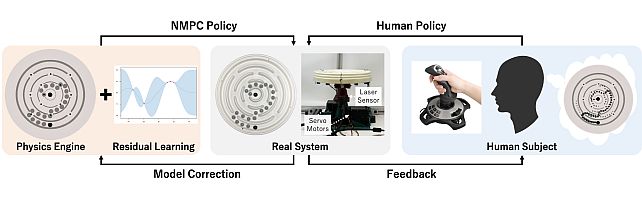
Circular Maze Environment -
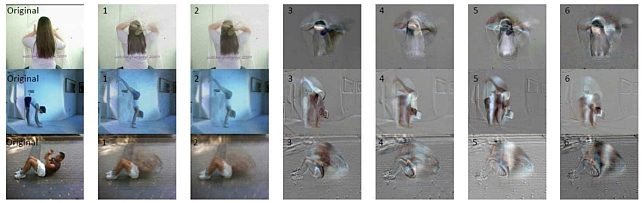
Discriminative Subspace Pooling -
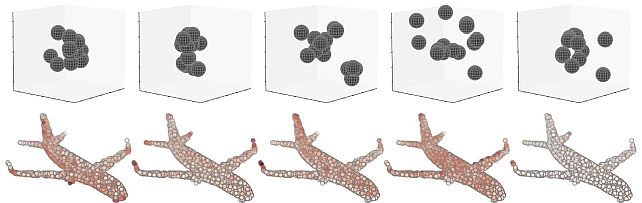
Kernel Correlation Network -
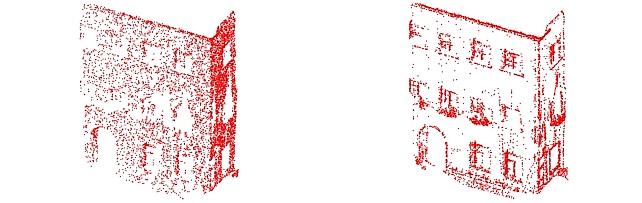
Fast Resampling on Point Clouds via Graphs -
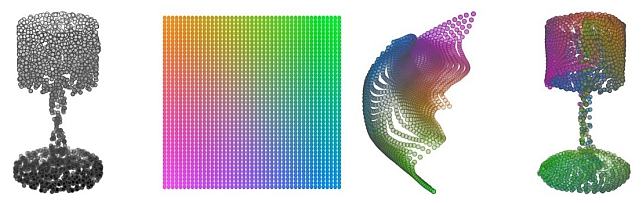
FoldingNet -
MERL Shopping Dataset -
Joint Geodesic Upsampling -
Plane Extraction using Agglomerative Clustering -
MERL BRDF Database
-