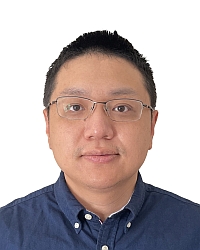
Jing Liu
- Phone: 617-621-7584
- Email:
-
Position:
Research / Technical Staff
Principal Research Scientist -
Education:
Ph.D., University of California, San Diego, 2019 -
Research Areas:
Jing's Quick Links
-
Biography
Before joining MERL, Jing was an Illinois Future Faculty fellow at the Computer Science department of the University of Illinois, Urbana Champaign (UIUC). Prior to that, he was a Postdoctoral Research Associate at the Coordinated Science Lab of UIUC. His research interests include Trustworthy AI, Distributed Learning and Inference, Robust and Efficient Internet-of-Things (IoT), and green AI.
-
Recent News & Events
-
NEWS MERL contributes to IROS 2026 Date: September 27, 2026 - October 1, 2026
Where: The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
MERL Contacts: Siddarth Jain; Toshiaki Koike-Akino; Jing Liu; Daniel N. Nikovski; Arvind Raghunathan; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
Main Conference Paper
- ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation, Yunfu Deng and Daniel N. Nikovski (TR2026-141)
The work introduces a geometric representation for articulated-object manipulation, enabling robots to infer compact representations of previously unknown articulated mechanisms for downstream learning and control.
Workshop Papers
- Deliberate Practice: Learning Robot Skills under a Budget Shivam Vats, Sudarshan Harithas, Mete Akbulut, Arvind Raghunathan, and George Konidaris (TR2026-147)
- ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies, Haodi Hu, Chung-Ta Huang, Jing Liu, Ye Wang, Kei Suzuki, Matthew Brand, and Toshiaki Koike-Akino (TR2026-148)
- Test-Time Attention: Can Robots Better Follow Commands? Jing Liu, Ye Wang, Kei Suzuki, and Toshiaki Koike-Akino (TR2026-142)
- Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation, Chak Lam Shek, Ye Wang, Jing Liu, Kei Suzuki, Pratap Tokekar, and Toshiaki Koike-Akino (TR2026-149)
- DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments, Harsh Singh, Kei Suzuki, Ye Wang, Jing Liu, Paola Cascante-Bonilla, and Toshiaki Koike-Akino (TR2026-146)
Together, these works address a range of challenges in modern robotics, including articulated-object manipulation, efficient robot skill learning, vision-language-action policies, test-time adaptation, autonomous factory operation, and dynamic manipulation. The paper on ReCoVLA was nominated as a spotlight talk.
Robotics Community Contributions
MERL Principal Research Scientist Dr. Siddarth Jain participated in the IEEE Robotics and Automation Letters (RA-L) editorial board meeting at IROS. Dr. Jain serves as an Associate Editor of RA-L, contributing to the peer-review and editorial activities of the robotics research community.
Former MERL scientist Dr. Diego Romeres was also among the organizers of the 1st International Workshop on Industrial Applications of Robot Learning (IARL 2026). The workshop brought together researchers from academia and industry to discuss how advances in robot learning can be translated into reliable and scalable real-world industrial robotic systems.
Humanoid IKEA Assembly Challenge
MERL also participated in the IROS 2026 Humanoid IKEA Assembly Challenge with Team MEL-Craft. The team achieved first place in the competition, demonstrating autonomous humanoid manipulation capabilities for a challenging furniture-assembly task. The MEL-Craft team included MERL researchers Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Haodi Hu, Harsh Singh, Chak Lam Shek, and Maxwell Asselmeier. The competition achievement is highlighted separately in MERL's related award announcement.
About IROS
The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) is a major international robotics conference bringing together researchers, engineers, and industry practitioners working across intelligent robots and systems. IROS 2026 took place in Pittsburgh from September 27 to October 1, 2026.
- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
-
NEWS MERL Presents 4 Main Conference Papers and 6 Workshop Papers at ICML 2026 Date: July 6, 2026 - July 11, 2026
Where: COEX, Seoul, South Korea
MERL Contacts: Moitreya Chatterjee; Anoop Cherian; Stefano Di Cairano; Toshiaki Koike-Akino; Christopher R. Laughman; Jing Liu; Suhas Lohit; Kuan-Chuan Peng; Alexander Schperberg; Ye Wang; Gordon Wichern
Research Areas: Artificial Intelligence, Computer Vision, Machine Learning, Signal ProcessingBrief- MERL researchers are proud to present 4 main conference papers and 6 workshop papers at ICML 2026. ICML, taking place from July 6-11 in Seoul, South Korea, is a premier international conference in machine learning.
Main Conference Papers with MERL Authors:
1. Understanding Dynamic Compute Allocation in Recurrent Transformers by Ibraheem Muhammad Moosa, Suhas Lohit, Ye Wang, Moitreya Chatterjee, and Wenpeng Yin.
2. LLawCo: Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior by Qinhong Zhou, Chuang Gan, and Anoop Cherian.
3. Memory-Distilled Selection for Noise-Robust Anomaly Detection by Sirojbek Safarov, Jaewoo Park, Yoon G. Jung, Kuan-Chuan Peng, Wonchul Kim, Seongdeok Bang, and Octavia Camps.
4. Partial Ring Scan: Revisiting Scan Order in Vision State Space Models by Yi-Kuan Hsieh, Kuan-Chuan Peng, Xin Li, Ming-Ching Chang, Yu-Chee Tseng, and Jun-Wei Hsieh.
Workshop Papers with MERL Authors:
1. WISE: Weighted Iterative Society-of-Experts for Multimodal Multi-Agent Debate with Probabilistic Consensus by Anoop Cherian, Suhas Lohit, and Kuan-Chuan Peng. (Workshop on Scalable Learning and Optimization for Efficient Multimodal AI Agents (SCALE))
2. MIRROR: Multisensory Implicit Rejection-sampled RObotic policy by Amisha Bhaskar, Pratap Tokekar, Stefano Di Cairano, and Alexander Schperberg. (Workshop on Structured Probabilistic Inference & Generative Modeling)
3. Reinforced Neural Processes: Memory-Efficient Time-Series Forecasting with a World-Feedback-Trained Memory Policy by Nibraas Khan, Gordon Wichern, and Christopher R. Laughman. (Workshop on Reinforcement Learning from World Feedback (RLxF))
4. Connecting Low-Rank Adapters and Policy Stability in GRPO Fine-Tuning by Antonin Rottman, Francesco Tonin, Yongtao Wu, Toshiaki Koike-Akino, and Volkan Cevher. (Workshop on Connecting Low-rank Representations in AI (CoLorAI))
5. EinSort: Sorting is All We Need for Tensorizing LLM by Toshiaki Koike-Akino, Jing Liu, and Ye Wang. (Workshop on Connecting Low-rank Representations in AI (CoLorAI))
6. Temper and Tilt Lead to SLOP: Reward Hacking Mitigation with Inference-Time Alignment by Ye Wang, and Jing Liu, and Toshiaki Koike-Akino. (Workshop on Agents in the Wild: Safety, Security, and Beyond)
- MERL researchers are proud to present 4 main conference papers and 6 workshop papers at ICML 2026. ICML, taking place from July 6-11 in Seoul, South Korea, is a premier international conference in machine learning.
See All News & Events for Jing -
-
Awards
-
AWARD MERL Wins Awards at NeurIPS LLM Privacy Challenge Date: December 15, 2024
Awarded to: Jing Liu, Ye Wang, Toshiaki Koike-Akino, Tsunato Nakai, Kento Oonishi, Takuya Higashi
MERL Contacts: Toshiaki Koike-Akino; Jing Liu; Ye Wang
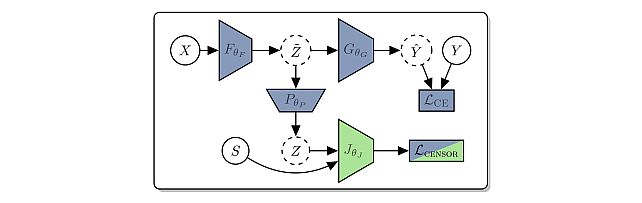
Research Areas: Artificial Intelligence, Machine Learning, Information SecurityBrief- The Mitsubishi Electric Privacy Enhancing Technologies (MEL-PETs) team, consisting of a collaboration of MERL and Mitsubishi Electric researchers, won awards at the NeurIPS 2024 Large Language Model (LLM) Privacy Challenge. In the Blue Team track of the challenge, we won the 3rd Place Award, and in the Red Team track, we won the Special Award for Practical Attack.
-
-
Research Highlights
-
MERL Publications
- , "Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.BibTeX TR2026-149 PDF
- @inproceedings{Shek2026sep,
- author = {Shek, Chak.Lam and Wang, Ye and Liu, Jing and Suzuki, Kei and Tokekar, Pratap and Koike-Akino, Toshiaki},
- title = {{Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-149}
- }
- , "DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.BibTeX TR2026-146 PDF
- @inproceedings{Singh2026sep,
- author = {Singh, Harsh and Suzuki, Kei and Wang, Ye and Liu, Jing and Cascante-Bonilla, Paola and Koike-Akino, Toshiaki},
- title = {{DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-146}
- }
- , "Test-Time Attention: Can Robots Better Follow Commands?", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) IARL Workshop, September 2026.BibTeX TR2026-142 PDF
- @inproceedings{Liu2026sep,
- author = {Liu, Jing and Wang, Ye and Suzuki, Kei and Koike-Akino, Toshiaki},
- title = {{Test-Time Attention: Can Robots Better Follow Commands?}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) IARL Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-142}
- }
- , "ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.BibTeX TR2026-148 PDF
- @inproceedings{Hu2026sep,
- author = {Hu, Haodi and Huang, Chung-Ta and Liu, Jing and Wang, Ye and Suzuki, Kei and Brand, Matthew and Koike-Akino, Toshiaki},
- title = {{ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-148}
- }
- , "Vibe Patenting: Evaluating LLM Judges for Professional Patent-Drafting Agents", arXiv, September 2026.BibTeX arXiv
- @article{Koike-Akino2026sep,
- author = {{Koike-Akino, Toshiaki and Blaykhman, Vlad and Wang, Ye and Liu, Jing and Vinokur, Gennadiy V.}},
- title = {{Vibe Patenting: Evaluating LLM Judges for Professional Patent-Drafting Agents}},
- journal = {arXiv},
- year = 2026,
- month = sep,
- url = {https://arxiv.org/abs/2609.13422}
- }
- , "Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, September 2026.
-
Other Publications
- , "Robust mean estimation in high dimensions: An outlier fraction agnostic and efficient algorithm", 2022 IEEE International Symposium on Information Theory (ISIT), 2022, pp. 1115-1120.BibTeX
- @Inproceedings{deshmukh2022robust,
- author = {Deshmukh, Aditya and Liu, Jing and Veeravalli, Venugopal V},
- title = {Robust mean estimation in high dimensions: An outlier fraction agnostic and efficient algorithm},
- booktitle = {2022 IEEE International Symposium on Information Theory (ISIT)},
- year = 2022,
- pages = {1115--1120},
- organization = {IEEE}
- }
- , "CoPur: Certifiably Robust Collaborative Inference via Feature Purification", Advances in Neural Information Processing Systems, 2022.BibTeX
- @Inproceedings{liu2022copur,
- author = {Liu, Jing and Xie, Chulin and Koyejo, Oluwasanmi O and Li, Bo},
- title = {CoPur: Certifiably Robust Collaborative Inference via Feature Purification},
- booktitle = {Advances in Neural Information Processing Systems},
- year = 2022
- }
- , "Rvfr: Robust vertical federated learning via feature subspace recovery", NeurIPS Workshop New Frontiers in Federated Learning: Privacy, Fairness, Robustness, Personalization and Data Ownership, 2021.BibTeX
- @Inproceedings{liu2021rvfr,
- author = {Liu, Jing and Xie, Chulin and Kenthapadi, Krishnaram and Koyejo, Sanmi and Li, Bo},
- title = {Rvfr: Robust vertical federated learning via feature subspace recovery},
- booktitle = {NeurIPS Workshop New Frontiers in Federated Learning: Privacy, Fairness, Robustness, Personalization and Data Ownership},
- year = 2021
- }
- , "Information flow optimization in inference networks", ICASSP 2020-2020 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP), 2020, pp. 8289-8293.BibTeX
- @Inproceedings{deshmukh2020information,
- author = {Deshmukh, Aditya and Liu, Jing and Veeravalli, Venugopal V and Verma, Gunjan},
- title = {Information flow optimization in inference networks},
- booktitle = {ICASSP 2020-2020 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP)},
- year = 2020,
- pages = {8289--8293},
- organization = {IEEE}
- }
- , "Sparse Bayesian learning for robust PCA: Algorithms and analyses", IEEE Transactions on Signal Processing, Vol. 67, No. 22, pp. 5837-5849, 2019.BibTeX
- @Article{liu2019sparse,
- author = {Liu, Jing and Rao, Bhaskar D},
- title = {Sparse Bayesian learning for robust PCA: Algorithms and analyses},
- journal = {IEEE Transactions on Signal Processing},
- year = 2019,
- volume = 67,
- number = 22,
- pages = {5837--5849},
- publisher = {IEEE}
- }
- , "Robust PCA via ℓ0-ℓ1 Regularization", IEEE Transactions on Signal Processing, Vol. 67, No. 2, pp. 535-549, 2018.BibTeX
- @Article{liu2018robust,
- author = {Liu, Jing and Rao, Bhaskar D},
- title = {Robust PCA via $$\backslash$ell \_ $\{$0$\}$ $-$$\backslash$ell \_ $\{$1$\}$ $ Regularization},
- journal = {IEEE Transactions on Signal Processing},
- year = 2018,
- volume = 67,
- number = 2,
- pages = {535--549},
- publisher = {IEEE}
- }
- , "Robust Linear Regression via ℓ0 Regularization", IEEE Transactions on Signal Processing, Vol. 66, No. 3, pp. 698-713, 2017.BibTeX
- @Article{liu2017robust,
- author = {Liu, Jing and Cosman, Pamela C and Rao, Bhaskar D},
- title = {Robust Linear Regression via $$\backslash$ell\_0 $ Regularization},
- journal = {IEEE Transactions on Signal Processing},
- year = 2017,
- volume = 66,
- number = 3,
- pages = {698--713},
- publisher = {IEEE}
- }
- , "Robust mean estimation in high dimensions: An outlier fraction agnostic and efficient algorithm", 2022 IEEE International Symposium on Information Theory (ISIT), 2022, pp. 1115-1120.
-
Software & Data Downloads
-
Videos