Dynamical Systems
Exploiting nonlinearity and shaping dynamics in creative and deeply mathematical ways.
We apply dynamical systems theory in applications ranging from space probe trajectory optimization to elevator suspensions. We also develop fundamental theory and computational methods in fluid dynamics.
Quick Links
-
Researchers
Stefano
Di Cairano
Avishai
Weiss
Yebin
Wang
Abraham P.
Vinod
Scott A.
Bortoff
Saviz
Mowlavi
Ankush
Chakrabarty
Purnanand
Elango
Christopher R.
Laughman
Hassan
Mansour
Alexander
Schperberg
Petros T.
Boufounos
Chungwei
Lin
Daniel N.
Nikovski
Hongtao
Qiao
Yanting
Ma
Abraham
Goldsmith
Jordan
Leung
Bingnan
Wang
Nobuyuki
Yoshikawa
Wael H.
Ali
Pedro
Miraldo
Philip V.
Orlik
Arvind
Raghunathan
Joshua
Rapp
Kento
Tomita
Pu
(Perry)
Wang
William S.
Yerazunis
Vedang M.
Deshpande
Jianlin
Guo
Toshiaki
Koike-Akino
Dehong
Liu
Kieran
Parsons
Zhaolin
Ren
Hongbo
Sun
Jinyun
Zhang
-
Awards
-
AWARD MERL intern and Researchers wins 2025 IEEE CCTA Best Student Paper Award Date: August 27, 2025
Awarded to: Yingjie Hu (Student, Intern), Karl Berntorp, Stefano Di Cairano (MERL Researchers)
MERL Contact: Stefano Di Cairano
Research Areas: Control, Dynamical Systems, Signal ProcessingBrief- MERL intern Yingjie Hu was recognized as the winner of the 2025 IEEE CCTA Best Student Paper Award for the paper "Optimal Measurement Projection in GNSS-RTK Factor Graph Optimization" written in collaboration with MERL Researchers Karl Berntorp and Stefano Di Cairano during the internship at MERL
The paper develops methods for measurement projections for reducing the computational burden of factor graph optimization algorithms in GNSS applications, thus enabling their use in real-time in a wider range of positioning applications.
The IEEE Conference on Control Technology and Application is the conference of the IEEE Control Systems Society focused on applications and technological advances of control systems
- MERL intern Yingjie Hu was recognized as the winner of the 2025 IEEE CCTA Best Student Paper Award for the paper "Optimal Measurement Projection in GNSS-RTK Factor Graph Optimization" written in collaboration with MERL Researchers Karl Berntorp and Stefano Di Cairano during the internship at MERL
-
AWARD MERL’s Paper on Wi-Fi Sensing Earns Top 3% Paper Recognition at ICASSP 2023, Selected as a Best Student Paper Award Finalist Date: June 9, 2023
Awarded to: Cristian J. Vaca-Rubio, Pu Wang, Toshiaki Koike-Akino, Ye Wang, Petros Boufounos and Petar Popovski
MERL Contacts: Petros T. Boufounos; Toshiaki Koike-Akino; Pu (Perry) Wang; Ye Wang
Research Areas: Artificial Intelligence, Communications, Computational Sensing, Dynamical Systems, Machine Learning, Signal ProcessingBrief- A MERL Paper on Wi-Fi sensing was recognized as a Top 3% Paper among all 2709 accepted papers at the 2023 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP 2023). Co-authored by Cristian Vaca-Rubio and Petar Popovski from Aalborg University, Denmark, and MERL researchers Pu Wang, Toshiaki Koike-Akino, Ye Wang, and Petros Boufounos, the paper "MmWave Wi-Fi Trajectory Estimation with Continous-Time Neural Dynamic Learning" was also a Best Student Paper Award finalist.
Performed during Cristian’s stay at MERL first as a visiting Marie Skłodowska-Curie Fellow and then as a full-time intern in 2022, this work capitalizes on standards-compliant Wi-Fi signals to perform indoor localization and sensing. The paper uses a neural dynamic learning framework to address technical issues such as low sampling rate and irregular sampling intervals.
ICASSP, a flagship conference of the IEEE Signal Processing Society (SPS), was hosted on the Greek island of Rhodes from June 04 to June 10, 2023. ICASSP 2023 marked the largest ICASSP in history, boasting over 4000 participants and 6128 submitted papers, out of which 2709 were accepted.
- A MERL Paper on Wi-Fi sensing was recognized as a Top 3% Paper among all 2709 accepted papers at the 2023 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP 2023). Co-authored by Cristian Vaca-Rubio and Petar Popovski from Aalborg University, Denmark, and MERL researchers Pu Wang, Toshiaki Koike-Akino, Ye Wang, and Petros Boufounos, the paper "MmWave Wi-Fi Trajectory Estimation with Continous-Time Neural Dynamic Learning" was also a Best Student Paper Award finalist.
See All Awards for MERL -
-
News & Events
-
NEWS MERL collaborator Yuri Shimane receives IFAC Young Author Applications Paper Prize Date: August 28, 2026
MERL Contacts: Stefano Di Cairano; Avishai Weiss
Research Areas: Control, Dynamical Systems, OptimizationBrief- MERL collaborator and former intern Prof. Yuri Shimane received the IFAC Young Author Applications Paper Prize at the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea for a paper co-authored with MERL researchers.
The award recognized Prof. Shimane paper, “Scenario-Based Model Predictive Control for Station Keeping on Near-Rectilinear Halo Orbit,” co-authored with Masafumi Isaji and MERL researchers Avishai Weiss and Stefano Di Cairano.
MERL congratulates Yuri and his co-authors on this recognition.
- MERL collaborator and former intern Prof. Yuri Shimane received the IFAC Young Author Applications Paper Prize at the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea for a paper co-authored with MERL researchers.
-
NEWS MERL researchers contribute six papers to IFAC World Congress 2026 Date: August 23, 2026 - August 28, 2026
Where: Busan, South Korea
MERL Contacts: Stefano Di Cairano; Alexander Schperberg; Abraham P. Vinod; Yebin Wang; Avishai Weiss
Research Areas: Control, Dynamical Systems, OptimizationBrief- MERL researchers contributed six papers to the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea. The IFAC World Congress, held every three years, brings together the international control community to share advances in control theory and applications.
The papers covered a range of topics in spacecraft control, autonomous robotics, and precision motion control:
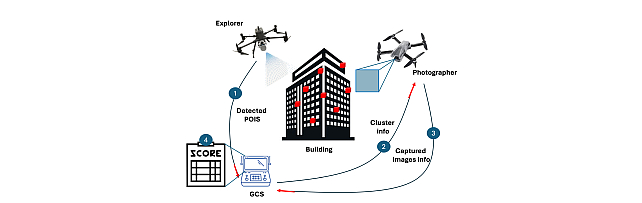
- Coordinated aerial inspection of infrastructure with heterogeneous drones, using drones with complementary sensing capabilities. MERL also released an open-source ROS 2 implementation accompanying the work.
- Geostationary satellite control using averaged dynamics, with the goal of extending the time between east–west station-keeping maneuvers.
- Scenario-based model predictive control for spacecraft station keeping on a near-rectilinear halo orbit.
- Parameter estimation for induction machines, enabling torque-bound construction for trajectory planning and control in precision positioning systems.
- Feedforward control with dual neural networks, improving motion tracking when load-side position measurements are only partially available.
- Constrained sampling-based model predictive control for contact-rich robotics, combining sampling-based exploration with gradient-based refinement for safe and precise robot motion.
In addition to the paper presentations, MERL researcher Abraham Vinod delivered an invited talk at the workshop “Trustworthy Data-Driven Control: From Finite Samples to Robust Guarantees.” His talk discussed data-driven environmental monitoring and decision-making under uncertainty.
- MERL researchers contributed six papers to the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea. The IFAC World Congress, held every three years, brings together the international control community to share advances in control theory and applications.
See All News & Events for Dynamical Systems -
-
Internships
-
OR0330: Internship - EMT Simulation of Data-Center Power Systems
-
MS0326: Internship - Scalable Numerical Solvers for Systems of Learned Dynamical Components
-
ST0348: Internship - AI-Aided Fluid Modeling and Engineering Design
See All Internships for Dynamical Systems -
-
Openings
-
MS0268: Research Scientist - Plasma Modeling and Control
-
SA0297: Postdoctoral Research Fellow - AI for Science
See All Openings at MERL -
-
Recent Publications
- , "PRISM: Bridging Multimodality and Real-Time Control in Multisensory Policies", Conference on Robot Learning (CoRL), November 2026.BibTeX TR2026-169 PDF
- @inproceedings{Bhaskar2026nov,
- author = {Bhaskar, Amisha and Tokekar, Pratap and {Di Cairano}, Stefano and Schperberg, Alexander},
- title = {{PRISM: Bridging Multimodality and Real-Time Control in Multisensory Policies}},
- booktitle = {Conference on Robot Learning (CoRL)},
- year = 2026,
- month = nov,
- url = {https://www.merl.com/publications/TR2026-169}
- }
- , "Induction Machines for Precision Positioning: Part I - Parameter Estimation", World Congress of the International Federation of Automatic Control (IFAC), October 2026.BibTeX TR2026-168 PDF
- @inproceedings{Zhao2026oct,
- author = {Zhao, Qianhong and Wang, Yebin and Sato, Go and Fujita, Tomoya},
- title = {{Induction Machines for Precision Positioning: Part I - Parameter Estimation}},
- booktitle = {World Congress of the International Federation of Automatic Control (IFAC)},
- year = 2026,
- month = oct,
- url = {https://www.merl.com/publications/TR2026-168}
- }
- , "Successive Convexification for Passively-Safe Spacecraft Rendezvous on Near Rectilinear Halo Orbit", AIAA Journal of Guidance Control and Dynamics, DOI: 10.2514/1.G009357, pp. 1-16, October 2026.BibTeX TR2026-167 PDF
- @article{Elango2026oct,
- author = {Elango, Purnanand and Vinod, Abraham P. and Kitamura, Kenji and Acikmese, Behcet and {Di Cairano}, Stefano and Weiss, Avishai},
- title = {{Successive Convexification for Passively-Safe Spacecraft Rendezvous on Near Rectilinear Halo Orbit}},
- journal = {AIAA Journal of Guidance Control and Dynamics},
- year = 2026,
- pages = {1--16},
- month = oct,
- doi = {10.2514/1.G009357},
- issn = {0731-5090},
- url = {https://www.merl.com/publications/TR2026-167}
- }
- , "Adaptive Observer-Based Detection of Inter-Turn Short-Circuit and Demagnetization Faults in Permanent Magnet Synchronous Motors", IEEE Industrial Electronics Society (IECON), October 2026.BibTeX TR2026-158 PDF
- @inproceedings{Yang2026oct2,
- author = {Yang, Ge and Wang, Yebin and Liu, Dehong and Lin, Chungwei and Wang, Bingnan},
- title = {{Adaptive Observer-Based Detection of Inter-Turn Short-Circuit and Demagnetization Faults in Permanent Magnet Synchronous Motors}},
- booktitle = {IEEE Industrial Electronics Society (IECON)},
- year = 2026,
- month = oct,
- url = {https://www.merl.com/publications/TR2026-158}
- }
- , "Physics-Informed Deep B-Spline Networks", Transactions on Machine Learning Research, October 2026.BibTeX TR2026-156 PDF
- @article{Wang2026oct,
- author = {Wang, Zhuoyuan and Romagnoli, Raffaele and Mowlavi, Saviz and Nakahira, Yorie},
- title = {{Physics-Informed Deep B-Spline Networks}},
- journal = {Transactions on Machine Learning Research},
- year = 2026,
- month = oct,
- url = {https://www.merl.com/publications/TR2026-156}
- }
- , "Spatio-temporal monitoring using energy-constrained, sensing robots", IEEE Transactions on Automation Science and Engineering (T-ASE), September 2026.BibTeX TR2026-144 PDF Video
- @article{Buyukkocak2026sep,
- author = {Buyukkocak, Ali and {Di Cairano}, Stefano and Vinod, Abraham P.},
- title = {{Spatio-temporal monitoring using energy-constrained, sensing robots}},
- journal = {IEEE Transactions on Automation Science and Engineering (T-ASE)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-144}
- }
- , "Model Parameter Identification for Induction Motor Fault Diagnosis", International Conference on Electrical Machines (ICEM), September 2026.BibTeX TR2026-122 PDF
- @inproceedings{Benninger2026sep,
- author = {Benninger, Moritz and Wang, Bingnan and Inoue, Hiroshi},
- title = {{Model Parameter Identification for Induction Motor Fault Diagnosis}},
- booktitle = {International Conference on Electrical Machines (ICEM)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-122}
- }
- , "OpInf-LLM: Parametric PDE Solving with LLMs via Operator Inference", Transactions on Machine Learning Research, August 2026.BibTeX TR2026-155 PDF
- @article{Wang2026aug,
- author = {Wang, Zhuoyuan and Hu, Hanjiang and Deng, Xiyu and Mowlavi, Saviz and Nakahira, Yorie},
- title = {{OpInf-LLM: Parametric PDE Solving with LLMs via Operator Inference}},
- journal = {Transactions on Machine Learning Research},
- year = 2026,
- month = aug,
- url = {https://www.merl.com/publications/TR2026-155}
- }
- , "PRISM: Bridging Multimodality and Real-Time Control in Multisensory Policies", Conference on Robot Learning (CoRL), November 2026.
-
Videos
-
Software & Data Downloads