Signal Processing
Acquisition and processing of information.
Our research in the area of signal processing encompasses a wide range of work in the areas of communications, sensing, estimation, localization, and speech and visual information processing. We explore novel approaches for signal acquisition and coding, methods to filter and recover signals in the presence of noise and other degrading factors, and techniques that infer meaning from the processed signals.
Quick Links
-
Researchers
Toshiaki
Koike-Akino
Philip V.
Orlik
Kieran
Parsons
Pu
(Perry)
Wang
Ye
Wang
Petros T.
Boufounos
Hassan
Mansour
Stefano
Di Cairano
Dehong
Liu
Yebin
Wang
Bingnan
Wang
Jianlin
Guo
Joshua
Rapp
Yanting
Ma
Matthew
Brand
Chungwei
Lin
Hongbo
Sun
Jinyun
Zhang
Abraham
Goldsmith
Suhas
Lohit
Tim K.
Marks
Wael H.
Ali
Ankush
Chakrabarty
Saviz
Mowlavi
Anthony
Vetro
Avishai
Weiss
Vedang M.
Deshpande
Jonathan
Le Roux
Pedro
Miraldo
Abraham P.
Vinod
William S.
Yerazunis
Anoop
Cherian
Radu
Corcodel
Chiori
Hori
Huifang
Sun
Kenji
Inomata
Jing
Liu
-
Awards
-
AWARD MERL Team Wins IROS 2026 Humanoid IKEA Assembly Challenge Date: October 1, 2026
Awarded to: Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, Ye Wang, Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu
MERL Contacts: Toshiaki Koike-Akino; Jing Liu; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
The challenge asked teams to develop autonomous robot policies for a Unitree G1 humanoid robot to assemble an IKEA UTTER table from its component parts. The robot had to perform the task autonomously at the competition venue, requiring capabilities including perception, bimanual manipulation, spatial reasoning, planning, and control. Human intervention was penalized, and teams were evaluated based on assembly progress and completion time.
MERL competed as MEL-Craft and achieved first place in the competition. The result demonstrates progress toward reliable humanoid robots capable of performing complex, contact-rich manipulation tasks in real-world environments, an important direction for physical AI and general-purpose robotic systems.
The MERL team members were Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu.
The Humanoid IKEA Assembly Challenge was held as part of IROS 2026, the IEEE/RSJ International Conference on Intelligent Robots and Systems.
- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
-
AWARD MERL Team Wins DCASE 2026 Challenge on Anomalous Sound Detection for Machine Condition Monitoring Date: June 30, 2026
Awarded to: Takuya Fujimura, Gordon Wichern, Yoshiki Masuyama, Christoph Boeddeker, Kohei Saijo, Julius Richter, Takahiro Edo, and Jonathan Le Roux
MERL Contacts: Christoph Boeddeker; Jonathan Le Roux; Yoshiki Masuyama; Julius Richter; Gordon Wichern
Research Areas: Artificial Intelligence, Machine Learning, Signal Processing, Speech & AudioBrief- MERL's Speech & Audio team ranked 1st out of 51 teams in the DCASE 2026 Challenge’s Task 2, “Noise-aware Unsupervised Anomalous Sound Detection for Machine Condition Monitoring.” The team was led by MERL intern Takuya Fujimura, and also included Gordon Wichern, Yoshiki Masuyama, Christoph Boeddeker, Kohei Saijo, Julius Richter, Takahiro Edo, and Jonathan Le Roux.
The IEEE AASP Challenge on Detection and Classification of Acoustic Scenes and Events (DCASE Challenge), started in 2013, has been organized yearly since 2016, and gathers challenges on multiple tasks related to the detection, analysis, and generation of sound events. This year, the DCASE 2026 Challenge received 421 submissions from 135 teams across seven tasks.
The MERL team won Task 2, Noise-aware Unsupervised Anomalous Sound Detection for Machine Condition Monitoring, which aims at building noise-robust systems for automatically detecting machine failure via microphones when only normal machine operating data is available for system development. Task 2 was by far the most popular out of the 7 DCASE 2026 tasks, with 51 teams submitting 168 entries. The MERL team's system was built around MERL’s recently proposed paradigm of noise-aware self-supervised learning, which extracts noise robust features leveraging two-channel recordings, in which one microphone is used to capture noise. Anomaly detection is then performed in the extracted denoised feature space using advanced score normalization. The team's best submission obtained a composite score of 70.24% on five evaluation machines, largely outperforming the 2nd best team's 65.45%.
MERL also participated in Task 4, Spatial Semantic Segmentation of Sound Scenes (S5) and placed 3rd out of 10 teams in separation performance. Our cascaded system consists of universal sound separation with source counting, source classification, and class-aware refinement, where the separation and refinement modules are built upon MERL's TF-Locoformer separation technology. Notably, the team's best submission obtained a label prediction accuracy of 76.92% on the evaluation set, largely outperforming the 2nd best team's 65.54%.
- MERL's Speech & Audio team ranked 1st out of 51 teams in the DCASE 2026 Challenge’s Task 2, “Noise-aware Unsupervised Anomalous Sound Detection for Machine Condition Monitoring.” The team was led by MERL intern Takuya Fujimura, and also included Gordon Wichern, Yoshiki Masuyama, Christoph Boeddeker, Kohei Saijo, Julius Richter, Takahiro Edo, and Jonathan Le Roux.
-
AWARD MERL intern and Researchers wins 2025 IEEE CCTA Best Student Paper Award Date: August 27, 2025
Awarded to: Yingjie Hu (Student, Intern), Karl Berntorp, Stefano Di Cairano (MERL Researchers)
MERL Contact: Stefano Di Cairano
Research Areas: Control, Dynamical Systems, Signal ProcessingBrief- MERL intern Yingjie Hu was recognized as the winner of the 2025 IEEE CCTA Best Student Paper Award for the paper "Optimal Measurement Projection in GNSS-RTK Factor Graph Optimization" written in collaboration with MERL Researchers Karl Berntorp and Stefano Di Cairano during the internship at MERL
The paper develops methods for measurement projections for reducing the computational burden of factor graph optimization algorithms in GNSS applications, thus enabling their use in real-time in a wider range of positioning applications.
The IEEE Conference on Control Technology and Application is the conference of the IEEE Control Systems Society focused on applications and technological advances of control systems
- MERL intern Yingjie Hu was recognized as the winner of the 2025 IEEE CCTA Best Student Paper Award for the paper "Optimal Measurement Projection in GNSS-RTK Factor Graph Optimization" written in collaboration with MERL Researchers Karl Berntorp and Stefano Di Cairano during the internship at MERL
See All Awards for Signal Processing -
-
News & Events
-
NEWS MERL contributes to IROS 2026 Date: September 27, 2026 - October 1, 2026
Where: The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
MERL Contacts: Siddarth Jain; Toshiaki Koike-Akino; Jing Liu; Daniel N. Nikovski; Arvind Raghunathan; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
Main Conference Paper
- ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation, Yunfu Deng and Daniel N. Nikovski (TR2026-141)
The work introduces a geometric representation for articulated-object manipulation, enabling robots to infer compact representations of previously unknown articulated mechanisms for downstream learning and control.
Workshop Papers
- Deliberate Practice: Learning Robot Skills under a Budget Shivam Vats, Sudarshan Harithas, Mete Akbulut, Arvind Raghunathan, and George Konidaris (TR2026-147)
- ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies, Haodi Hu, Chung-Ta Huang, Jing Liu, Ye Wang, Kei Suzuki, Matthew Brand, and Toshiaki Koike-Akino (TR2026-148)
- Test-Time Attention: Can Robots Better Follow Commands? Jing Liu, Ye Wang, Kei Suzuki, and Toshiaki Koike-Akino (TR2026-142)
- Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation, Chak Lam Shek, Ye Wang, Jing Liu, Kei Suzuki, Pratap Tokekar, and Toshiaki Koike-Akino (TR2026-149)
- DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments, Harsh Singh, Kei Suzuki, Ye Wang, Jing Liu, Paola Cascante-Bonilla, and Toshiaki Koike-Akino (TR2026-146)
Together, these works address a range of challenges in modern robotics, including articulated-object manipulation, efficient robot skill learning, vision-language-action policies, test-time adaptation, autonomous factory operation, and dynamic manipulation. The paper on ReCoVLA was nominated as a spotlight talk.
Robotics Community Contributions
MERL Principal Research Scientist Dr. Siddarth Jain participated in the IEEE Robotics and Automation Letters (RA-L) editorial board meeting at IROS. Dr. Jain serves as an Associate Editor of RA-L, contributing to the peer-review and editorial activities of the robotics research community.
Former MERL scientist Dr. Diego Romeres was also among the organizers of the 1st International Workshop on Industrial Applications of Robot Learning (IARL 2026). The workshop brought together researchers from academia and industry to discuss how advances in robot learning can be translated into reliable and scalable real-world industrial robotic systems.
Humanoid IKEA Assembly Challenge
MERL also participated in the IROS 2026 Humanoid IKEA Assembly Challenge with Team MEL-Craft. The team achieved first place in the competition, demonstrating autonomous humanoid manipulation capabilities for a challenging furniture-assembly task. The MEL-Craft team included MERL researchers Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Haodi Hu, Harsh Singh, Chak Lam Shek, and Maxwell Asselmeier. The competition achievement is highlighted separately in MERL's related award announcement.
About IROS
The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) is a major international robotics conference bringing together researchers, engineers, and industry practitioners working across intelligent robots and systems. IROS 2026 took place in Pittsburgh from September 27 to October 1, 2026.
- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
-
NEWS MERL Presents Five Papers at IEEE Quantum Week 2026 Date: September 13, 2026 - September 18, 2026
Where: Toronto, Canada
MERL Contact: Toshiaki Koike-Akino
Research Areas: Applied Physics, Artificial Intelligence, Machine Learning, Optimization, Signal ProcessingBrief- MERL is pleased to announce that five papers have been accepted to the 2026 IEEE International Conference on Quantum Computing and Engineering (QCE), also known as IEEE Quantum Week 2026, held September 13–18, 2026, in Toronto, Canada.
The papers highlight MERL’s recent advances in quantum computing, spanning hardware-efficient quantum state preparation, quantum low-density parity-check (QLDPC) code design, graph-cover-based code construction, machine-learning-assisted code search, and reinforcement-learning-guided quantum error correction. Together, these works address important challenges toward more efficient and reliable quantum computing systems.
The five papers are:
- “Near-Lower-Bound Approximate Quantum State Preparation with Hardware-Efficient Circuits” — Toshiaki Koike-Akino (TR2026-131)
- “Reinforcement-Learning-Guided Multi-Branch Decoding of Quantum LDPC Codes” — Vahid Nourozi, Toshiaki Koike-Akino, and David Mitchell (TR2026-130)
- “Q-Learning Base Search Voltage-Labeled Covers for Weight-Six Bivariate-Bicycle Quantum LDPC Codes” — Vahid Nourozi, David Mitchell, and Toshiaki Koike-Akino (TR2026-132)
- “Collision-Voltage Design of Directional Covers for Bivariate Bicycle Quantum LDPC Codes” — Vahid Nourozi, David Mitchell, and Toshiaki Koike-Akino (TR2026-133)
- “Base-Preserving APM/Voltage Lifts of Bivariate Bicycle Quantum LDPC Codes” — Vahid Nourozi, David Mitchell, and Toshiaki Koike-Akino (TR2026-129)
- MERL is pleased to announce that five papers have been accepted to the 2026 IEEE International Conference on Quantum Computing and Engineering (QCE), also known as IEEE Quantum Week 2026, held September 13–18, 2026, in Toronto, Canada.
See All News & Events for Signal Processing -
-
Research Highlights
-
Internships
-
EA0237: Internship - Condition Monitoring and Fault Diagnosis
-
ST0238: Internship - Multi-Modal Sensing and Understanding
-
EA0234: Internship - Multi-modal sensor fusion for predictive maintenance
See All Internships for Signal Processing -
-
Openings
-
SA0297: Postdoctoral Research Fellow - AI for Science
-
CI0177: Postdoctoral Research Fellow - Agentic AI
-
ST0175: Postdoctoral Research Fellow - Quantum Technologies
See All Openings at MERL -
-
Recent Publications
- , "Demagnetization Fault Detection in PMSMs with Online Inductance Estimation", IEEE Energy Conversion Congress and Exposition (ECCE), October 2026.BibTeX TR2026-152 PDF
- @inproceedings{Yang2026oct,
- author = {Yang, Ge and Wang, Yebin and Goldsmith, Abraham and Lin, Chungwei and Wang, Bingnan},
- title = {{Demagnetization Fault Detection in PMSMs with Online Inductance Estimation}},
- booktitle = {IEEE Energy Conversion Congress and Exposition (ECCE)},
- year = 2026,
- month = oct,
- url = {https://www.merl.com/publications/TR2026-152}
- }
- , "Radar Sensing in Industrial and Mobile Robotics: A Review", IEEE Sensors Journal, September 2026.BibTeX TR2026-145 PDF
- @inproceedings{Pandharipande2026sep,
- author = {Pandharipande, Ashish and Wang, Pu and Hakobyan, Gor},
- title = {{Radar Sensing in Industrial and Mobile Robotics: A Review}},
- booktitle = {IEEE Sensors Journal},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-145}
- }
- , "Near-Lower-Bound Approximate Quantum State Preparation with Hardware-Efficient Circuits", IEEE International Conference on Quantum Computing and Engineering (QCE), September 2026.BibTeX TR2026-131 PDF Presentation
- @inproceedings{Koike-Akino2026sep2,
- author = {{Koike-Akino, Toshiaki}},
- title = {{Near-Lower-Bound Approximate Quantum State Preparation with Hardware-Efficient Circuits}},
- booktitle = {IEEE International Conference on Quantum Computing and Engineering (QCE)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-131}
- }
- , "Reinforcement-Learning-Guided Multi-Branch Decoding of Quantum LDPC Codes", IEEE International Conference on Quantum Computing and Engineering (QCE), September 2026.BibTeX TR2026-130 PDF Presentation
- @inproceedings{Nourozi2026sep2,
- author = {{Nourozi, Vahid and Koike-Akino, Toshiaki and Mitchell, David}},
- title = {{Reinforcement-Learning-Guided Multi-Branch Decoding of Quantum LDPC Codes}},
- booktitle = {IEEE International Conference on Quantum Computing and Engineering (QCE)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-130}
- }
- , "Base-Preserving APM/Voltage Lifts of Bivariate Bicycle Quantum LDPC Codes", IEEE International Conference on Quantum Computing and Engineering (QCE), September 2026.BibTeX TR2026-129 PDF Presentation
- @inproceedings{Nourozi2026sep,
- author = {{Nourozi, Vahid and Mitchell, David and Koike-Akino, Toshiaki}},
- title = {{Base-Preserving APM/Voltage Lifts of Bivariate Bicycle Quantum LDPC Codes}},
- booktitle = {IEEE International Conference on Quantum Computing and Engineering (QCE)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-129}
- }
- , "Q-Learning Base Search Voltage-Labeled Covers for Weight-Six Bivariate-Bicycle Quantum LDPC Codes", IEEE International Conference on Quantum Computing and Engineering (QCE), September 2026.BibTeX TR2026-132 PDF Presentation
- @inproceedings{Nourozi2026sep3,
- author = {{Nourozi, Vahid and Mitchell, David and Koike-Akino, Toshiaki}},
- title = {{Q-Learning Base Search Voltage-Labeled Covers for Weight-Six Bivariate-Bicycle Quantum LDPC Codes}},
- booktitle = {IEEE International Conference on Quantum Computing and Engineering (QCE)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-132}
- }
- , "Net-Voltage Screening of Bivariate-Bicycle Tanner-Graph Covers", IEEE International Conference on Quantum Computing and Engineering (QCE), September 2026.BibTeX TR2026-133 PDF Presentation
- @inproceedings{Nourozi2026sep4,
- author = {{Nourozi, Vahid and Mitchell, David and Koike-Akino, Toshiaki}},
- title = {{Net-Voltage Screening of Bivariate-Bicycle Tanner-Graph Covers}},
- booktitle = {IEEE International Conference on Quantum Computing and Engineering (QCE)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-133}
- }
- , "Deep-Unfolded Autofocus Imaging for Distributed MIMO Radar", IEEE International Conference on Image Processing (ICIP), September 2026.BibTeX TR2026-128 PDF
- @inproceedings{Terada2026sep,
- author = {Terada, Tsubasa and Mansour, Hassan and Boufounos, Petros T. and Takahashi, Ryuhei},
- title = {{Deep-Unfolded Autofocus Imaging for Distributed MIMO Radar}},
- booktitle = {IEEE International Conference on Image Processing (ICIP)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-128}
- }
- , "Demagnetization Fault Detection in PMSMs with Online Inductance Estimation", IEEE Energy Conversion Congress and Exposition (ECCE), October 2026.
-
Videos
-
Software & Data Downloads
-
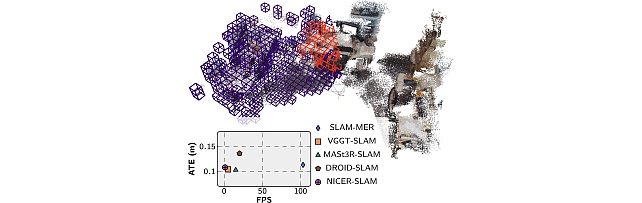
Mitsubishi Electric Research framework for visual SLAM -
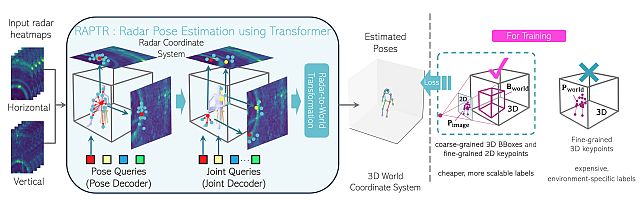
Radar-based 3D Pose Estimation using Transformer -
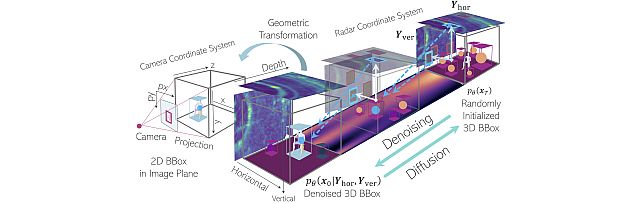
multi-view Radar object dEtection with 3D bounding boX diffusiOn -
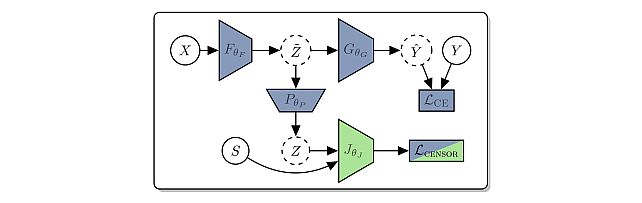
Stabilizing Subject Transfer in EEG Classification with Divergence Estimation -
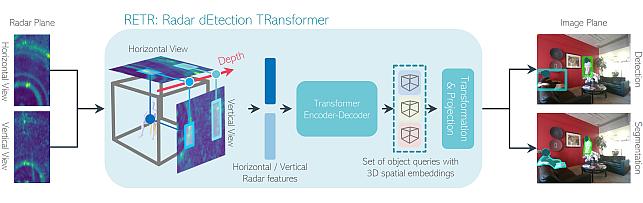
Radar dEtection TRansformer -
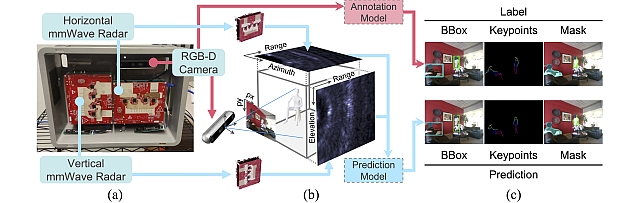
Millimeter-wave Multi-View Radar Dataset -
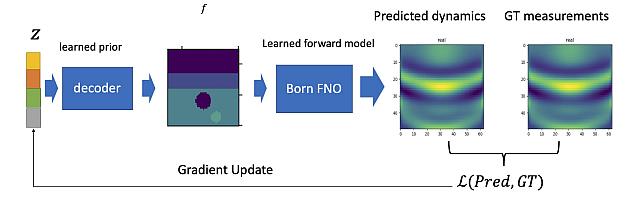
Learned Born Operator for Reflection Tomographic Imaging -
Nonparametric Score Estimators -
Convergent Inverse Scattering using Optimization and Regularization -
One-Bit CRB
-