TR2026-101
Coordinated aerial inspection of infrastructure with heterogeneous drones
-
- , "Coordinated aerial inspection of infrastructure with heterogeneous drones", World Congress of the International Federation of Automatic Control (IFAC), July 2026.BibTeX TR2026-101 PDF Software
- @inproceedings{Folorunsho2026jul,
- author = {Folorunsho, Samuel and Hayner, Christopher and {Di Cairano}, Stefano and Vinod, Abraham P.},
- title = {{Coordinated aerial inspection of infrastructure with heterogeneous drones}},
- booktitle = {World Congress of the International Federation of Automatic Control (IFAC)},
- year = 2026,
- month = jul,
- url = {https://www.merl.com/publications/TR2026-101}
- }
- , "Coordinated aerial inspection of infrastructure with heterogeneous drones", World Congress of the International Federation of Automatic Control (IFAC), July 2026.
-
MERL Contacts:
-
Research Areas:
Abstract:
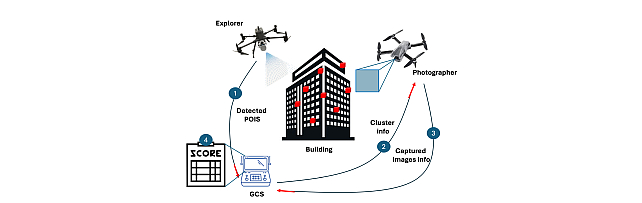
We consider coordinated aerial inspection of large-scale infrastructure using a team of explorer (LiDAR-equipped) and photographer (camera-equipped) drones. We propose a hierarchical framework that combines constrained trajectory generation with multi-agent task assignment to perform inspection efficiently and safely. A key feature of our approach is the use of sequential convex programming for photographer trajectory generation under dynamics, perception, and communication constraints. We also validate our approach in a ROS2/PX4 high-fidelity simulator that extends an existing ROS1-based CARIC benchmark (Cao et al., 2025). The proposed approach typically achieves shorter scoring duration than a baseline A*-based planner while maintaining comparable inspection quality and balanced drone utilization. The code for this work is publicly available at https://github.com/merlresearch/ros2_caric.
Software & Data Downloads
Related News & Events
-
NEWS MERL researchers contribute six papers to IFAC World Congress 2026 Date: August 23, 2026 - August 28, 2026
Where: Busan, South Korea
MERL Contacts: Stefano Di Cairano; Alexander Schperberg; Abraham P. Vinod; Yebin Wang; Avishai Weiss
Research Areas: Control, Dynamical Systems, OptimizationBrief- MERL researchers contributed six papers to the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea. The IFAC World Congress, held every three years, brings together the international control community to share advances in control theory and applications.
The papers covered a range of topics in spacecraft control, autonomous robotics, and precision motion control:
- Coordinated aerial inspection of infrastructure with heterogeneous drones, using drones with complementary sensing capabilities. MERL also released an open-source ROS 2 implementation accompanying the work.
- Geostationary satellite control using averaged dynamics, with the goal of extending the time between east–west station-keeping maneuvers.
- Scenario-based model predictive control for spacecraft station keeping on a near-rectilinear halo orbit.
- Parameter estimation for induction machines, enabling torque-bound construction for trajectory planning and control in precision positioning systems.
- Feedforward control with dual neural networks, improving motion tracking when load-side position measurements are only partially available.
- Constrained sampling-based model predictive control for contact-rich robotics, combining sampling-based exploration with gradient-based refinement for safe and precise robot motion.
In addition to the paper presentations, MERL researcher Abraham Vinod delivered an invited talk at the workshop “Trustworthy Data-Driven Control: From Finite Samples to Robust Guarantees.” His talk discussed data-driven environmental monitoring and decision-making under uncertainty.
- MERL researchers contributed six papers to the 23rd IFAC World Congress 2026, held August 23–28 in Busan, South Korea. The IFAC World Congress, held every three years, brings together the international control community to share advances in control theory and applications.